Centre de robotique d’assistance
Le Centre de robotique d’assistance fait œuvre de pionnier dans la recherche en interaction humain-robot, en explorant comment les robots peuvent assister les utilisateurs à domicile, en institution et en milieu industriel.
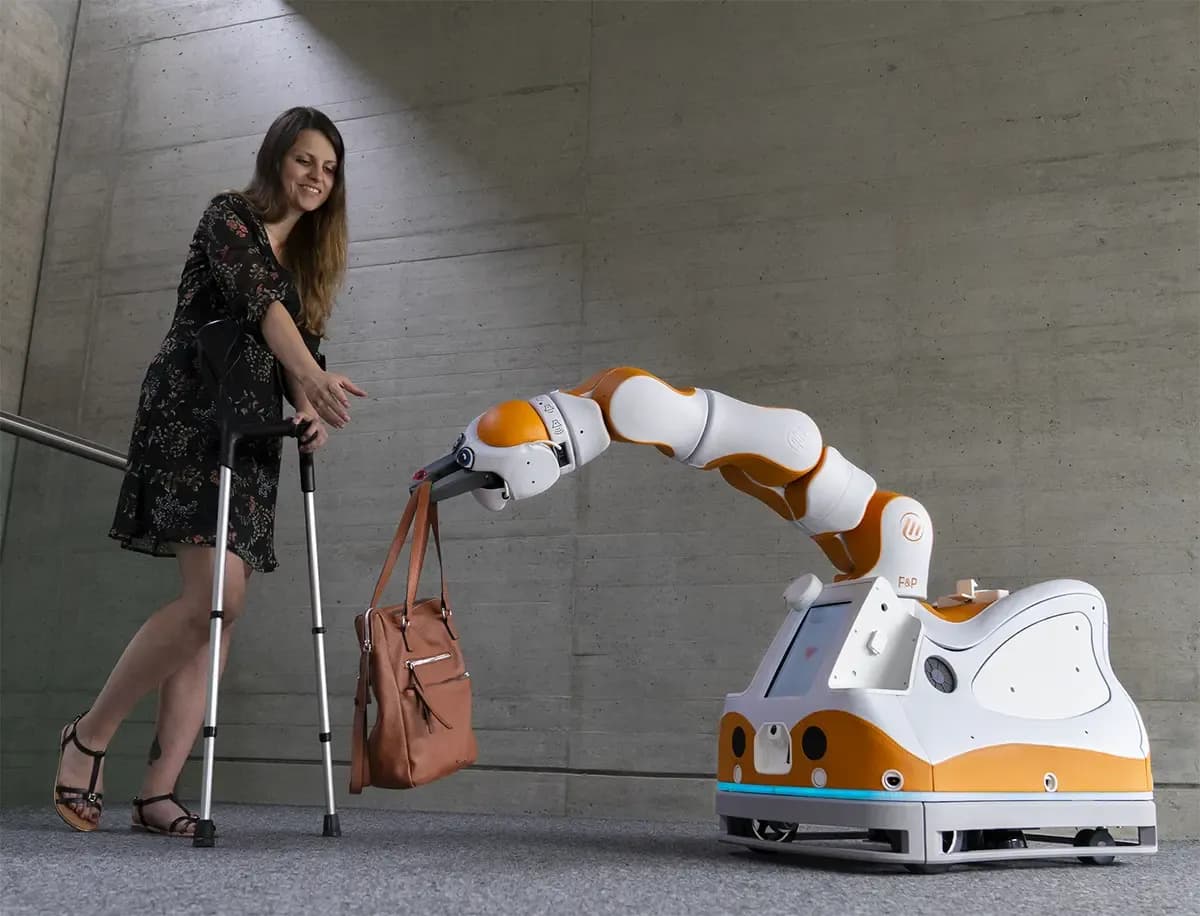
Le Centre de robotique d’assistance fait progresser la recherche en interaction humain-robot en explorant comment les robots peuvent soutenir les personnes à domicile ainsi que dans les environnements de soins et professionnels. Sa mission est d’améliorer la vie des personnes âgées, des personnes en situation de handicap, des travailleurs et des opérateurs industriels en développant des systèmes fondés à la fois sur l’intelligence sociale et sur l’assistance physique. Grâce à des applications telles que le soutien physique et la manipulation de l’environnement, le Centre vise à renforcer l’autonomie des personnes dans leurs activités quotidiennes et leur travail.
Le Centre s’attache à permettre aux robots d’acquérir rapidement de nouvelles compétences à partir d’un minimum de démonstrations et d’interactions, en s’appuyant sur son expertise en collaboration humain-robot, en apprentissage par démonstration et en programmation par l’utilisateur final. Il tire également parti de ses compétences en perception du comportement humain à travers les signaux sociaux et non verbaux – notamment le suivi du regard et de l’attention, l’analyse audio et vocale, la modélisation de la communication et l’informatique affective – afin de concevoir des systèmes robotiques bien acceptés.
L’un des objectifs clés est de favoriser la collaboration interdisciplinaire entre les groupes de recherche de l’Idiap, en réunissant des compétences en vision par ordinateur, traitement automatique du langage naturel, traitement audio et de la parole, technologies de la langue des signes et commande optimale. Cela permet de développer des modèles d’interaction complets et des systèmes d’IA dotés d’une riche intelligence sociale, favorisant des interactions fluides et naturelles entre humains et robots.
Le Centre dialogue activement avec les parties prenantes en coorganisant des événements avec des partenaires académiques et industriels, des institutions de santé et des utilisateurs finaux, favorisant ainsi des collaborations autour des technologies d’IA incarnée. Ces efforts visent à renforcer les capacités des travailleurs et des utilisateurs dans des domaines tels que la santé, l’industrie manufacturière et l’agriculture, tout en développant des systèmes robotiques qui aident les personnes en situation de handicap à accomplir leurs tâches quotidiennes.
Le centre soutient les programmes de recherche Human-AI Teaming et AI for Life de l’Idiap.
Qui sommes-nous
Projets
Rationale:
In Switzerland, 1 769 000 people are living with disabilities, and might need frequent physical therapy to maintain functions. However, most patients can only access therapy at a low frequency (due to insurance or availability of therapists) which might be insufficient. We believe that robotic-assisted physical therapy could help address this gap by helping patients to exercise more frequently. Due to the variability between pathologies and individuals, these physical human-robot interactions can take different forms and should be set by a therapist. However, as pointed in Van der Loos et al. (2016), there are critical needs for interfaces to personalize these physical human-robot interaction that can be used by non-experts in robotics.
Objectives:
This project’s main objective is to push the science on physical human-robot interaction and develop user-centered tools that can be shared with the community to personalize physically assistive behaviors. More precisely, this project aims to answer the following question: “How can end users easily and intuitively specify complex physically interactive robot behaviors?”, using rehabilitation robotics as a use case.
The aims of the project are: (1) Develop new flexible behavior encodings for kinesthetic interaction between robots and people; (2) Develop multi-modal interfaces to specify rich kinesthetic behaviors; (3) Validate these systems in user studies with clinicians and patients.
Methods:
This project approaches the challenge of end-user design of kinesthetic robot behavior through participatory design (PD), a development method centered around the users of the technology. We will collaborate with an application partner (Centre Neu’Rhône) to develop interaction paradigms (Thread 1), behavior encodings (Thread 2), and interfaces (Thread 3) to support greater personalization and usability of physical human-robot interaction. Finally, we will evaluate our system in multiple user studies and conclude the project with a summative study where patients will be able to interact with the robot with little supervision (Thread 4). The project will leverage previous work from the PI (PD research, end-user programming, assistive robotics, and shared autonomy) and partners at the institution (learning from demonstration and behavior encodings) to develop parameterizable motions that can be easily and intuitively specified by end users, such as physical therapists.
Expected Results:
With this work, we aim to develop and make available new tools for end users to create rich kinesthetic behaviors. Through our user studies, we will demonstrate the applicability of our approach to rehabilitation therapy, showing that collaborative robots can be flexible tools to safely simplify access to therapy. Finally, we will open-source our findings to help the community build upon the research made in this project. These contributions are significant for the community, as there is today little research on the specification of rich kinesthetic behaviors directly by end users in allied health domains. Most research in end-user specification of physical behaviors remains centered on industrial application and misses challenges specific to this domain.
Impact:
This project will impact the robotic community by developing new control algorithms and interfaces for safe and personalizable physical human-robot interaction. On top of disseminating knowledge though publications in scientific venues (conferences and journals), this project will provide an open source flexible software implementation for the wider community. However, the impact will also reach beyond roboticists and researchers. By taking a user-centered approach, this project will help form the next generation of multidisciplinary researchers. Finally, this project also aims to have societal impacts by making personalized physical therapy more accessible and communicating with the public through workshops and other outreach activities.
Recent advances in anthropomorphic and multi-limbs robots have led to an increased interest in exploiting these platforms for human-robot collaboration (HRC). HRC is challenging in multiple aspects, covering perception, learning, control and planning levels. The underlying problems share as common ground that they need some form of distances to be measured, which are used as some form of cost functions that need to be minimized. Distance measurement is thus an essential common ingredient at the core of robotics. For control, these distances are typically used in the form of residuals that are corrected by a feedback controller. For planning, trajectories minimizing the total distance between two points correspond to geodesic paths (for Euclidean distances, these paths correspond to straight segments between the two points). By extension, these distances are also the core component to model diffusion processes and kernel function to model (co)variations and uncertainty.
In HORACE, we will treat these distances from a geometric perspective, which boils down to the selection of efficient representations and manifolds to specify these distances. The goal is to measure distances by going beyond Euclidean distances between two points, but to instead consider distances between other geometric objects and to account for manifolds that are not Euclidean, which is often the case in robotics. We will then exploit these distance measures in the form of kernel functions that can be used in Gaussian processes to account for variations and uncertainty.
By leveraging our previous expertise, we will demonstrate the developed approaches in several human-robot collaboration scenarios involving joint physical collaboration, assembly, manipulation of deformable objects, all with high degree of freedom robots, in particular, the TALOS humanoid robot readily available at JSI. We will investigate how the control of a humanoid robot can be effectively achieved by using the proposed geometric descriptors and how the geodesics in such encoding can be used for effective planning.
HORACE will lead to novel methodological developments yielding more efficient human-robot collaboration and better understanding of its inherent geometrical structure. The three partners each bring knowledge and equipment that complement the others. Idiap brings knowledge on the geometric perspectives, UNIZG-FER on planning and HRC and JSI on humanoid robots and HRC. The complementarity of the partners will enable concrete advancements in the field of human-robot collaboration.